Actuators for Humanoid Robots

Calculate output per mass and peak demand for humanoid robot actuators, then prepare a supplier RFQ worksheet.

RFQ calculator

Calculate output per mass and peak demand. Example inputs only; actuator fit needs supplier test data.

All numeric fields are required; preferences are optional. Thermal margin, speed and actuator fit are not calculated.

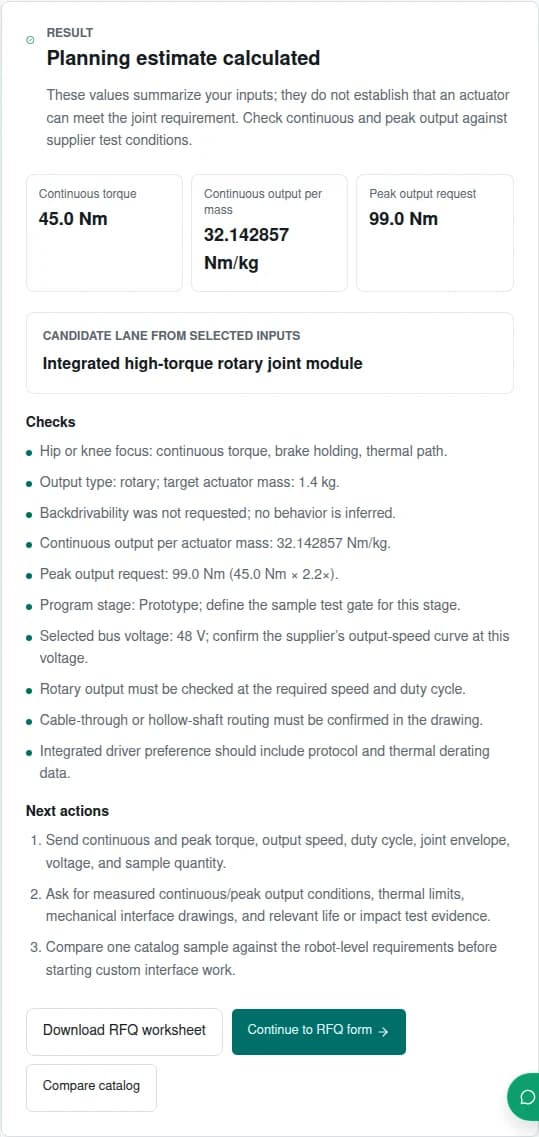
Live output per mass: 32.142857 Nm/kg

Result

Run the RFQ preflight

This tool calculates continuous output per actuator mass and a peak output request. The arithmetic does not establish whether a specific actuator fits your robot.

Continuous torque
--
Continuous output per mass
--
Peak output request
--

Candidate lane from selected inputs

Awaiting inputs

Checks

  • Continuous output and actuator mass are used for the per-mass estimate.
  • Boundary values are flagged against this tool’s stated input range.
  • Supplier curves, drawings, and sample tests are still required.

Next actions

  1. Review the output type and joint zone, then run the preflight.
Executive summary

What Counts as Actuators for Humanoid Robots?

Selecting actuators for humanoid robots means matching motor, transmission, feedback, drive and thermal design to the joint duty. Compare joint mechanical impedance, continuous torque limits and dynamic impact tolerance alongside peak output. McKinsey estimates actuators at 40%–60% of hardware BOM [S10]; this is an industry estimate, not a platform quote. Compare complete installed systems, not isolated peak torque headlines. For the broader sourcing sequence, see the humanoid actuator procurement guide.

40%–60%
Hardware BOM estimate [S10]
Jmotor × N²
Reflected rotor inertia; fixed rotor
Test data
Required for peak duration [S7]
Dual feedback
Can improve load positioning [S6]
  • Define joint loads and trajectories before comparing actuator architecture.
  • Separate continuous output from peak duration; match speed, temperature and mounting conditions [S7].
  • Compare reflected motor inertia using Jmotor × N² for the same rotor, then include friction, transmission inertia and controller response [S4].
  • Choose sensing from output accuracy and fault-detection needs. Load-side feedback can improve control but does not remove mechanical compliance [S6].
  • Include transmission, cooling, brake, bearings and electronics in mass and cost comparisons.
  • Validate communication deadlines and power-loss holding with the selected hardware [S8, S9].

Integrated Humanoid Actuator Mechatronic Stack

Hardware Architecture

Conceptual layout of one possible rotary module with dual feedback, cable routing and a holding brake. Components and specifications vary by design; this is not a manufacturer cross-section.

Integrated Humanoid Actuator Cross-Sectional Diagram
Illustrative stack only. Load feedback can improve positioning [S6]; it does not remove transmission elasticity. Verify wiring clearance and brake switching behavior [S8] on the complete joint.
Sensing & control

Motor and Load Feedback & Control-Loop Planning

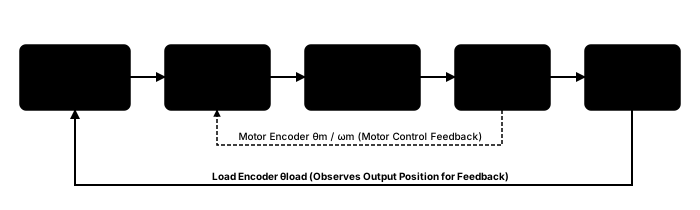
Motor-side and load-side feedback can improve positioning through a compliant transmission [S6]. Select sensing, update rates and controller tuning from the actual error budget. Dual encoders do not remove mechanical backlash.

Dual-Loop Cascaded Control Architecture

Conceptual topology [S6]

Motor and load feedback serve different control roles [S6]. This conceptual cascade has no fixed bandwidth: sampling rate, tuning and achievable response depend on the drive and mechanical system.

Cascaded Dual-Loop Feedback Control Block Diagram
Conceptual control topology, not an EPOS4 implementation specification. Motor feedback supports motor control; load feedback observes output position. Neither encoder resolution nor absolute sensing is fixed by the dual-loop principle.
Audience & boundaries

Who This Actuator Sizing Guide Is For

Clear application boundaries prevent costly engineering mismatches between humanoid dynamics and conventional industrial automation.

Recommended Applications (Best Fit)

  • Humanoid Robot Joint Sizing: Mechatronics engineers sizing joint modules across bipedal legs, arms, waists, necks, and dexterous hands.
  • Architecture Selection: System architects comparing QDD, strain-wave, cycloidal, and linear roller screw topologies for dynamic impact vs static holding.
  • Supplier RFQ Preparation: Hardware procurement leaders structuring vendor RFQs with verified continuous vs peak torque, thermal limits, and encoder protocols.

Applications requiring a different assessment

  • Heavy Articulated Industrial Arms: Use the arm-specific payload, reach, safety and duty-cycle requirements; this humanoid RFQ worksheet is insufficient for final selection.
  • Hobby RC & Toy Robotics: Check the actual feedback, duty and interface specifications; hobby servo control signals do not establish industrial suitability.
  • Constant-Speed Conveyors & Pumps: Use a drive selection process based on the continuous load, starting duty and required speed regulation.
Joint map & topology

Kinematic Distribution of Actuators for Humanoid Robots

The distribution of actuators across a humanoid robot depends on joint mechanical impedance, dynamic impact velocity, and spatial packaging constraints.

Humanoid Skeleton Kinematic Actuator Distribution

Topology by Joint Duty

Candidate topologies by joint duty, not a standard body-wide specification. Derive loads from your robot model; no common torque or mass range is established here.

Upper Limbs & Neck

Rotary or Remote Transmission

  • • Shoulder & Elbow: Derive loads from arm self-weight, payload reach and acceleration.
  • • Wrist & Hands: Compare compact rotary, linear and tendon paths against the tool task.
  • • Primary Constraint: Low mass, compact packaging, output accuracy and harness motion.

Torso & Pelvic Core

Rotary or Linkage Drive

  • • Waist Yaw & Pitch: Check upper-body gravity loads and sustained holding duty.
  • • Hip Roll & Yaw: Simulate coupled axis loads and contact transitions.
  • • Primary Constraint: Quantified compliance, cable routing and validated power-loss holding.

Lower Legs & Ankles

High-Load Rotary or Linear Linkage

  • • Knee Extension: Compare rotary torque-speed and linear force-stroke requirements.
  • • Ankle Pitch/Roll: Evaluate full-range moment arms, contact loads and side-load paths.
  • • Primary Constraint: High shock overload capacity, low distal inertia.
Moving actuator mass proximally can reduce distal inertia; linkage mass, friction and packaging may offset that benefit. Compare the complete mechanism and gait energy rather than a transmission name.
Specifications matrix

Joint-by-Joint Actuator Sizing & Mechanical Requirements Matrix

RFQ requirements worksheet, not a standard humanoid specification. N/A means no comparable verified value is available here. Derive loads, speed and axis count from your robot model and motion profiles.

Joint ZoneDoFPeak Torque/ForceContinuous OutputMax VelocityCandidate TopologiesDominant Mechanical Hazard
HipDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileRotary or linkage-drivenBody mass, payload, posture and gait dynamics; Coupled axis loads and impact spectrum
KneeDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileRotary or linear linkageLink inertia, contact forces and motion trajectory; Stroke/speed extremes and repeated impacts
AnkleDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileCompact rotary or push-pull linkageGround contact, balance and moment-arm map; Side loads, singularities and distal mass
TorsoDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileRotary with holding strategyUpper-body mass and acceleration; Power-loss load path and cable twist
ShoulderDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileRotary or remote transmissionPayload reach plus arm self-weight; Gravity holding and brake sizing
ElbowDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileRotary, cable or linkageForearm inertia and payload; Harness motion and thermal holding
WristDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileCompact rotary or remote driveTool inertia and positioning task; Mass, stiffness and angular accuracy
Hand / fingersDefine from kinematic modelN/A: derive from trajectoryN/A: derive from duty cycleN/A: derive from motion profileMiniature rotary or linearContact force and tendon routing; Friction, fatigue and pinch-force mapping
Architecture lanes

Pick the Actuator Lane Before Asking for a Quote

The preflight gives a candidate lane from your selections, not a verified fit. This table explains when each lane suits a program, key specifications, what evidence to request, and where trade-offs appear during prototype builds.

Actuator laneSpecification BoundaryBest fitEvidence to requestProcurement caution
Integrated rotary joint moduleModel-specific; request torque-speed and mass dataCompact rotary joints needing a packaged motor, transmission and feedbackContinuous and peak output at speed, peak duration, thermal mounting, backlash and brake behaviorIntegrated does not mean strain-wave or specified lost motion. Compare the whole module under identical test conditions.
QDD or low-ratio rotary moduleRatio and backdrive torque: verify per modelJoints where low reflected inertia and backdrive torque are prioritiesMotor inertia, measured backdrive torque, current-to-output torque calibration and impact testsA lower ratio reduces reflected motor inertia for the same rotor, but does not guarantee safe impacts or accurate current-based output torque.
Frameless torque motor stackMotor-only ratings; not directly comparable to module densityTeams integrating their own housing, bearings, transmission, cooling and controlsWinding data, motor torque constant, inertia, magnet temperature limits and mechanical tolerancesInclude bearings, reducer, brake, electronics and cooling in the finished joint mass and integration cost.
Linear actuator or screw-driven linkageForce-speed-stroke curve: verify per modelMechanisms designed around force, stroke and linkage geometryContinuous/peak force, stroke, speed, side-load limits, friction, life and changing perpendicular moment armJoint torque is force × perpendicular moment arm. Derive the moment arm from actual geometry over the full motion range.
Transmission mechanics

Transmission Benchmark: QDD vs. Strain-Wave vs. Cycloid vs. Roller Screw

Qualitative comparison with explicit unknowns. No cross-vendor torque-density, efficiency or overload dataset is established here. The strain-wave principle is documented in [S5]; the QDD study [S4] is a single exoskeleton, not a humanoid-wide benchmark. For every rotary topology, add transmission inertia to the reflected rotor term before comparing complete joints.

TechnologyRatio / LeadOutput per MassBacklashReflected InertiaBackdrivabilityShock OverloadCandidate Use / Limits
Low-ratio planetary / QDDModel-specific low reductionN/A: comparable module tests unavailableMeasure on selected assemblyJmotor × N² (rotor term only)Measure friction and backdrive torqueN/A: request repeated-impact evidenceCandidate for force-controlled joints; validate load case
Strain-waveModel-specific high reductionN/A: comparable module tests unavailableZero-backlash gearing; elastic deflection remains [S5]Jmotor × N² (rotor term only)Depends on ratio, friction, preload and controlN/A: check allowable transient torque and lifeCandidate for compact positioning; validate compliance
CycloidalModel-specificN/A: comparable module tests unavailableModel, preload and wear dependentJmotor × N² (rotor term only)Requires measurement; no universal category valueN/A: no generic overload percentageCandidate where load capacity and stiffness suit duty
Roller screw or ball screwLead in mm/revolution, not rotary ratioN/A: force density is not torque densityAxial play and stiffness depend on preloadRequires screw and linkage coordinate conversionDepends on lead, friction, preload and gearingN/A: check contact life and shock loadsCandidate for linkage-driven joints; validate full stroke

Reflected Rotor Inertia Scaling: Jreflected = Jmotor × N²

Assumed Jrotor = 0.0001 kg·m²

Arithmetic comparison for the same assumed rotor: its output-referred inertia scales with the square of reduction ratio N. Friction, gearing inertia and impact response require separate measurements.

8:1 example0.0064 kg·m² (64× rotor)
20:1 example0.0400 kg·m² (400× rotor)
50:1 example0.2500 kg·m² (2500× rotor)
80:1 example0.6400 kg·m² (6400× rotor)
Fixed-rotor example assuming rigid transmission. At N=80:1 the reflected rotor term is 100× that at N=8:1. This is not total joint inertia or an impact-safety prediction.
Linear actuation

Linear Screw Drives & Joint Linkage Kinematics

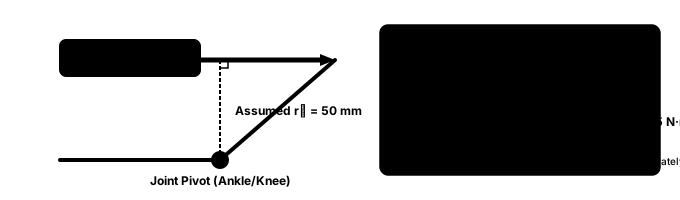
A proximal linear drive can move mass away from the foot, but the benefit depends on the complete linkage. Compute torque using the actual perpendicular moment arm at every pose; do not assume a universal sine relationship.

Linear Screw Linkage: Hypothetical Joint Example

τ(θ) = Faxial × r⊥(θ)

Converting axial push-pull actuator thrust into rotary joint torque depends on changing perpendicular moment arm geometry r⊥(θ) across the entire joint travel range.

Linear Screw Linkage Kinematic Diagram
Hypothetical arithmetic: 3,500 N × 0.050 m = 175 N·m and 3,500 N × 0.038 m = 133 N·m. Both perpendicular moment arms are assumed, not derived from the sketch. Derive r⊥(θ) from actual geometry over the full stroke, including singularities, losses and bearing reactions.
Thermal management

Thermal Dissipation, Duty Cycles, and In-Limb Derating

Continuous and peak ratings depend on the winding, ambient, mounting and cooling assumptions [S7]. No universal peak duration or cooling uplift is established here. Validate the final enclosed installation.

Cooling TopologyTorque RetentionPeak DurationThermal Time ConstantMass PenaltySealingEngineering Reality
Passive enclosed limbN/A: test in final installationN/A: supplier current/time/temperature limitN/A: measure winding and housing responseInclude housing and mountingN/A: enclosure-level qualificationDo not assume open-air catalog ratings apply. Record ambient, mounting, starting temperature and steady-state winding temperature [S7].
Conductive chassis heat pathN/A: test in final installationN/A: supplier current/time/temperature limitN/A: measure winding and housing responseInclude pads and structural changesN/A: enclosure-level qualificationValidate contact resistance, chassis heat rejection and neighboring heat sources; no universal torque uplift follows from adding a heat sink [S7].
Forced airN/A: test in final installationN/A: supplier current/time/temperature limitN/A: measure winding and housing responseInclude blower, filters and ductingN/A: enclosure-level qualificationMeasure airflow, noise and blocked-filter behavior. Ventilation and sealing require enclosure-specific validation.
Liquid jacketN/A: test in final installationN/A: supplier current/time/temperature limitN/A: measure winding and housing responseInclude coolant, hoses, pump and radiatorN/A: enclosure-level qualificationVerify coolant flow/temperature, leak containment, pump-fault behavior and full-system mass. Liquid cooling is not instantaneous or unlimited.

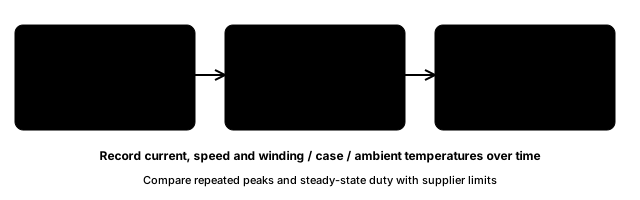
Thermal Path & Peak-Duration Evidence

Conceptual heat flow [S7]

Copper loss grows with current squared at a fixed resistance. Peak duration also depends on starting temperature, speed, repeated duty, drive limits and heat rejection; no universal time-to-trip curve applies.

Conceptual heat path from winding through housing to ambient; every thermal limit requires measurement
No numeric thermal envelope is established here. Test the complete installation, including sensor lag, adjacent heat sources and cooling faults. Winding insulation class alone does not define a safe operating temperature for magnets, bearings, electronics or touch surfaces.

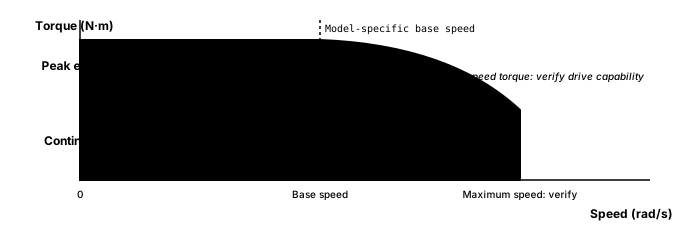
Actuator Torque-Speed (T-ω) Operating Boundaries

Conceptual positive quadrant

Conceptual positive torque-speed quadrant, not a measured product curve. Request continuous and peak envelopes at your bus voltage, temperature and cooling conditions, plus duration and repetition limits.

Torque versus Speed Operating Boundaries Chart
Illustrative envelopes have no numeric scale. Field weakening is available only where the motor and drive support it. Check braking and regeneration separately; this sketch shows neither the other quadrants nor a certified operating region. Peak output alone does not define an S3 duty rating.
Communications & electronics

Fieldbus Architecture: EtherCAT CoE vs. CAN FD vs. RS-485

Budget worst-case command and feedback traffic, synchronization, device processing and fault behavior. A protocol name or axis count alone cannot establish a control-loop rate [S9].

ProtocolBus Cycle RateJitterNode BudgetHarness WiringBandwidth EvaluationSystem Trade-off
EtherCATN/A: budget and measure end-to-endDC clock accuracy: <1 µs; not end-to-end jitter [S9]N/A: depends on payload, topology and cycleEthernet physical layer; specify cables and connectorsBudget command/feedback bytes and device processing per cycleSynchronization can help coordinated axes; requires compatible drives and a real-time master.
CAN FDN/A: calculate from message scheduleArbitration and implementation dependentN/A: no universal node cutoffShared differential bus; verify termination and stub lengthsInclude arbitration/data rates, frame overhead, priorities and fault trafficSegment buses if the measured schedule misses deadlines; axis count alone cannot prove saturation.
RS-485 with an application protocolN/A: protocol and implementation dependentPolling, scheduling and controller dependentN/A: transceiver and loading dependentDifferential physical layer; topology must suit protocolRS-485 alone specifies no control loop rate; Modbus is one possible protocolEvaluate the selected protocol against the required deadlines rather than inferring suitability from the physical layer.
Worked examples

Actuators for Humanoid Robots: 5 Hypothetical RFQ Examples

Assumed values illustrate reproducible arithmetic, not tested robots or product recommendations. Each example identifies missing evidence and a next action. Examples 1 and 5 can be reproduced in the calculator.

Example 1: Rotary RFQ arithmetic

Context: Hypothetical inputs, not a validated walking knee design.
Parameters: 45 Nm continuous; 1.4 kg; peak multiplier 2.2.
Candidate / Next Decision: Compare rotary candidates; architecture still open

45 ÷ 1.4 ≈ 32.1 Nm/kg; 45 × 2.2 = 99 Nm peak request. The calculator reproduces these numbers. Obtain speed, peak duration, cooling and impact evidence before selecting a sample.

Example 2: Shoulder gravity load

Context: Hypothetical 5 kg point payload at 0.75 m horizontal reach; g = 9.81 m/s².
Parameters: Payload-only static torque: 5 × 9.81 × 0.75 ≈ 36.8 Nm.
Candidate / Next Decision: Compare holding strategies and rotary modules

Add arm/link self-weight, acceleration and all relevant loads. 36.8 Nm is a lower-bound component of static torque, not a final actuator rating. Check brake engagement time and dynamic stopping separately [S8].

Example 3: Linear ankle linkage

Context: Hypothetical 3,500 N axial force with a 0.05 m perpendicular moment arm at one pose.
Parameters: Ideal joint torque at that pose: 3,500 × 0.05 = 175 Nm.
Candidate / Next Decision: Linear linkage candidate; full geometry needed

The moment arm changes with pose. Map force, stroke, speed, friction and side-load through the full motion range. The 175 Nm calculation does not prove continuous capacity or impact tolerance.

Example 4: Reflected motor inertia

Context: Hypothetical identical rotor inertia of 0.0001 kg·m²; ideal rigid reductions.
Parameters: 8:1 → 0.0064 kg·m²; 80:1 → 0.64 kg·m².
Candidate / Next Decision: Compare complete motor/transmission designs

The rotor contribution differs by 100× under this fixed-rotor assumption. Different motors, friction, compliance and controls can change the system comparison. This calculation does not predict gear fracture or safe contact.

Example 5: Hand linear-force request

Context: Hypothetical tendon actuator inputs, not fingertip force.
Parameters: 8 N continuous; 0.1 kg; peak multiplier 2.5.
Candidate / Next Decision: Compare miniature linear or remote tendon drives

8 ÷ 0.1 = 80 N/kg; 8 × 2.5 = 20 N peak axial request. Determine tendon routing losses, lever arms, stroke and speed before translating to fingertip force or claiming a pinch capability.

Humanoid actuator RFQ calculator result for 45 Nm, 1.4 kg and a 2.2 peak multiplier
Software run captured November 8, 2026, using the default rotary inputs: hip/knee, prototype, 45 Nm, 1.4 kg, 2.2× and 48 V. The result is 32.142857 Nm/kg and a 99 Nm peak request. This cropped calculator screenshot demonstrates arithmetic, not tested hardware performance or customer approval.
Evidence & empirical limits

Source-Backed Buying Assumptions & Evidence Limits

Published September 24, 2026; reviewed November 9, 2026. Published by Humanoid Robot Actuators. Next source review: May 9, 2027, or earlier if supplier specifications change. [S1]–[S10] refer to the source cards below. Diagrams are conceptual; worked numbers are hypothetical unless tied to a source. The sources do not replace supplier test data, but they explain which actuator claims should be verified before samples are approved. Where public data is proprietary, limits are explicitly flagged. For mass-normalized design context, read the humanoid actuator power-density guide.

[S1] Boston Dynamics electric Atlas announcement

Published April 17, 2024; checked November 9, 2026

Confirms the transition to electric Atlas. It does not provide actuator torque classes or supplier module specifications.

Open source

[S2] Tesla SI & Robotics: Optimus overview

Publication date not stated; checked November 9, 2026

Describes the Optimus program. This page does not disclose actuator counts, screw types, torque ratings, or thermal limits.

Open source

[S3] Apptronik Apollo 2 actuator overview

Publication date not stated; checked November 9, 2026

States a design target of 90%+ actuator energy efficiency. This company claim has no published operating point or independent validation on the page.

Open source

[S4] Yu et al.: quasi-direct-drive hip exoskeleton

Published April 1, 2020; checked November 9, 2026

Reports 17.5 Nm nominal torque, 0.4 Nm backdrive torque and 62.4 Hz bandwidth for one tested hip exoskeleton. These measurements are not specifications for humanoid leg joints.

Open source

[S5] Harmonic Drive: strain-wave and planetary principles

Publication date not stated; checked November 9, 2026

Explains strain-wave gearing and its zero-backlash characteristic. This does not establish zero elastic deflection, arbitrary impact tolerance, or complete actuator torque density.

Open source

[S6] maxon EPOS4: dual loop control

Updated August 29, 2024; checked November 9, 2026

Explains motor-side and load-side feedback and controller tuning. Load feedback can reduce positioning errors caused by compliance and backlash; it does not remove those mechanical properties.

Open source

[S7] Kollmorgen KBM series and linked selection guide

Catalog listed October 7, 2025; checked November 9, 2026

Lists model-specific continuous and peak stall ratings and links the selection guide. Request its winding, ambient, mounting and heat-sink conditions; a motor-only rating does not establish capacity in a sealed humanoid limb.

Open source

[S8] mayr ROBA-servostop Cobot operating instructions

Issue November 2022, sections 5.2.5 and 6.5; checked November 9, 2026

Specifies switching times and separate static/dynamic brake sizing. Engagement takes time; a holding brake alone does not establish safe stopping or prevent robot collapse.

Open source

[S9] Beckhoff XFC and distributed clocks

Publication date not stated; checked November 9, 2026

Describes sub-microsecond distributed-clock accuracy within Beckhoff XFC. This vendor capability is not a measured humanoid network result. Clock synchronization accuracy is not the same as total sensor-to-actuator latency or a guaranteed robot control bandwidth.

Open source

[S10] McKinsey humanoid supply-chain analysis

Published April 17, 2026; checked November 9, 2026

Estimates actuators at 40%–60% of hardware BOM. This industry analysis is not an audited platform BOM or a supplier quotation; scope and integration level affect the share.

Open source

Actuation cost share varies

McKinsey’s April 17, 2026 analysis [S10] estimates actuators at 40%–60% of humanoid hardware BOM. This is an industry estimate, not a universal per-platform figure; BOM boundaries and robot architectures vary.

Read the McKinsey analysis

Feedback improves observation, not mechanics

maxon’s dual-loop explanation [S6] separates motor and load feedback. Use it to plan output error measurements and controller tuning; do not infer a universal encoder resolution or bus rate.

Read the dual-loop explanation

Backdrivability is a design trade-off

Lower transmission ratios can reduce reflected rotor inertia and improve backdrivability, while reducing output torque for a given motor. The QDD study [S4] demonstrates one low-ratio design; impact response still depends on the complete joint, friction, compliance, controller, and load case.

Read the QDD study
Limits & failure modes

What the RFQ Preflight Can and Cannot Decide

The checker screens the initial architecture path. It cannot certify final actuator life, impact tolerance, sealing, controller stability, or robot-level safety. Those require sample bench testing and supplier-provided test data.

Risk ModeRoot CauseEvidence NeededMitigation Action
Thermal deratingCatalog conditions differ from enclosed installation.Torque-speed region, mounting, ambient and measured winding temperature [S7]Test the intended duty cycle to thermal equilibrium; respect supplier current/time limits.
Impact overloadLoad spectrum, inertia, compliance and controller response interact.Allowable transient loads, fatigue and relevant repeated-impact testsValidate the full joint. Neither low ratio nor a transmission name establishes impact safety.
Position error and oscillationBacklash, compliance, sensing and tuning affect output motion.Loaded output accuracy, hysteresis and closed-loop stability [S6]Select feedback and tune under actual loads; dual encoders cannot mechanically remove backlash.
Communication deadlinesTraffic schedule and device latency exceed control timing budget.Worst-case bus utilization, jitter and end-to-end timing [S9]Measure under maximum traffic and faults; adjust payload, cycle or bus segmentation.
Power-loss motionBrake torque, engagement delay or stopping energy is unsuitable.Brake switching times, static/dynamic ratings and safety analysis [S8]Verify a controlled stop and holding strategy; a holding brake is not a robot-level safety guarantee.
Magnet overheating or supply changeOperating temperature, demagnetizing field or material substitutions exceed design assumptions.Supplier magnet curves, rotor thermal estimate and change-control recordsConfirm temperature/current limits with the motor supplier. Winding temperature is not magnet temperature; Curie temperature is not an operating limit.
Integration cost and scene mismatchA motor-only price or mass omits the finished joint and test effort.BOM boundary, NRE, electronics, cooling, tooling, validation and spare-part termsCompare complete installed cost at stated quantity; sample first and postpone custom interfaces until baseline evidence is accepted.

Actuator Selection & Procurement Verification Gate

Engineering Flow
1

Kinematic & Dynamic Profiling

Extract joint torque-speed and angular acceleration profiles from full-body simulation (MuJoCo/Isaac Gym).

2

Electrical & Thermal Sizing

Verify continuous RMS torque against thermal dissipation; confirm peak multiplier and bus voltage margin.

3

Feedback, Bus & Safety Gates

Select feedback from the output error budget, measure communication deadlines, and validate stopping and power-loss holding.

4

Bench Dynamometer Validation

Benchmark catalog samples for thermal rise, backdrive friction, impact fatigue, and lost-motion hysteresis.

Structured 4-gate verification sequence prevents premature commitment to custom tooling before fundamental torque, thermal, and communication capabilities are validated on catalog samples.

Critical Actuator Failure Modes & Mitigation Matrix

Risk Gate

Flexspline Fatigue / Tooth Skip

Catastrophic Joint Lock

Root Cause: Repeated contact or fall loads exceeding the selected transmission limits.

Mitigation: Obtain transient torque and fatigue limits; test the full joint against the load spectrum. Low ratio alone does not establish impact safety.

Winding Overheat & Demag

Irreversible Torque Loss

Root Cause: Insufficient heat rejection or operation beyond winding, magnet or drive temperature limits.

Mitigation: Measure the installed thermal path and sensor response; set protection from the selected components, including sensor lag.

Fieldbus Jitter & Deadline Miss

Control Instability & Shaking

Root Cause: Worst-case scheduling, arbitration, retransmission or processing delays exceed the control deadline.

Mitigation: Measure end-to-end latency under fault traffic; adjust schedule, processing or segmentation. Clock accuracy is not total latency.

Holding Brake Engagement Lag

Post-E-Stop Sag / Collapse

Root Cause: Mechanical engagement delay and insufficient static or dynamic brake capacity under the actual load [S8].

Mitigation: Size stopping energy, load torque and engagement time with the supplier; test the power-loss load path. A holding brake alone does not guarantee a safe robot stop.

Hardware risk mitigation: Humanoid robot joint actuators operate under continuous dynamic shocks and tight thermal enclosures. Address these four critical failure modes before finalizing serial production orders.
RFQ package

Minimum Inputs to Send After the Tool Result

A useful humanoid actuator RFQ should require the supplier to demonstrate fit against the joint duty, not only against a catalog model name.

Joint data

joint zone, continuous and peak torque or force, output speed or stroke, duty cycle, impact or holding events, and ambient operating temperature

Mechanical data

outer diameter, axial length, mass target, flange mounting, output shaft or hollow bore for wiring, cable exit orientation, and drawing revision

Electrical data

bus voltage, controller location, required communication schedule, feedback interfaces, brake supply and switching requirements, fault behavior, and harness length

FAQ

Humanoid Actuator Selection & Sizing Questions

Selection, controls, evidence and sample-review questions. Source IDs refer to the evidence cards above.

What are the main actuators for humanoid robots?

Common candidates include packaged rotary modules, low-ratio QDD drives, frameless motor stacks and linear screw/linkage systems. These categories overlap: QDD describes a low-ratio drive approach, frameless describes motor packaging, and integrated rotary actuators package a motor, transmission and feedback. Reducer type, encoder count and drive integration are model-specific. Select against measured joint duty rather than body location alone.

How do engineering teams select actuators for a humanoid robot?

Start with a kinematic joint map, derive torque-speed or force-stroke trajectories, and define envelope, mass and communication constraints. Use this preflight worksheet to summarize continuous output per mass and peak requests, then compare candidate supplier hardware under identical thermal and mounting conditions.

What does reflected motor inertia tell me?

For an ideal rigid rotary reduction N, the rotor contribution referred to output is Jmotor × N². This is one system term. It does not alone predict tooth fracture, backdrive torque or safe contact; compare the full motor, transmission and control design.

Do dual encoders eliminate gearbox backlash?

No. Motor-side and load-side feedback can improve load positioning and compensate some transmission errors when properly tuned [S6]. Mechanical backlash, elastic deflection, friction and wear remain.

Is EtherCAT required for every humanoid joint?

No universal bus choice follows from joint count. Budget command and feedback traffic, device processing, synchronization and worst-case latency. EtherCAT distributed clocks support synchronized acquisition [S9]; CAN FD suitability depends on its actual message schedule.

How long can an actuator hold peak torque?

There is no universal time. Obtain the supplier current-time-temperature limits, starting temperature, speed, bus voltage and cooling assumptions. Continuous capacity must be validated in the final installation [S7].

Should I choose a roller screw or a ball screw?

Compare model-specific force-speed curves, lead, stroke, stiffness, preload, lubrication, backdrivability, life and cost under the same load spectrum. No generic load or life multiplier is established by the sources on this page.

What specification should I request first?

Request continuous output at speed with ambient, mounting and thermal conditions. Then confirm peak output duration and repeatability. Linear paths also need stroke, side-load and linkage geometry.

When should I consider QDD?

Consider low reduction when measured backdrive torque and reflected inertia matter. A published exoskeleton demonstrates this approach [S4], but does not validate humanoid impacts. Check motor size, current, heat and output torque accuracy.

When does a linear actuator make sense?

Consider a linear path when the joint geometry can accommodate stroke and linkage forces. Compute the changing perpendicular moment arm and check singularities, side loads, bearing reactions and full-range speed.

How much of a humanoid robot cost is in actuators?

McKinsey estimates 40%–60% of hardware BOM in its April 17, 2026 analysis [S10]. Treat this as an industry estimate; the platform, accounting scope, quantity and degree of integration determine the actual share.

What should a sample RFQ contain?

Include joint zone, continuous and peak output, peak duration, speed or stroke, duty cycle, mass and envelope, output interface, voltage, protocol, encoder and brake needs, harness routing, drawing revision, quantity and validation date.

Can one model serve every joint?

Joint loads, speed, packaging and feedback needs differ. Standardize only after comparing each joint duty; this page does not prescribe a universal number of frame sizes or torque classes.

What makes catalog comparisons misleading?

Peak versus continuous values, motor-only versus complete-module mass, and different thermal mounting or speed conditions are not directly comparable. Normalize those boundaries before ranking suppliers.

When should the first sample remain close to catalog form?

Use a catalog sample while validating curves, temperature, output accuracy, brake behavior and control stability. Custom flanges and connectors add cost and lead time before these uncertainties are resolved.

What evidence matters for walking legs?

Request output envelopes, repeated-load and impact tests relevant to the intended gait, transmission life, thermal conditions, sealing, cable routing and power-loss behavior. Architecture alone is not evidence of walking suitability.

What if supplier data is incomplete?

Mark missing values as unknown, request test conditions and agree a sample test plan. Compare another supplier if the evidence remains insufficient; avoid freezing a design around an unverified catalog claim.

What should I do when the preflight cannot establish fit?

Use the result as an RFQ worksheet and send the joint map, motion profile, envelope, interfaces and duty cycle for sample review. Thermal margin, fatigue life and robot safety require additional engineering and tests.

Does an AI controller announcement define servo requirements?

No. Obtain the specific platform command rate, latency budget, feedback format and fault behavior. An AI capability demonstration does not establish actuator bandwidth or hardware specifications.

Does a power-off holding brake guarantee a safe stop?

No. A spring-applied, electrically released brake takes time to engage. Check holding torque, dynamic braking energy, switching time and control sequencing for the selected brake [S8]. Robot stability and stopping safety require a system-level assessment.

How should magnet temperature limits be specified?

Request the supplier magnet grade, temperature-dependent demagnetization curves and permitted current/temperature envelope. Estimate rotor temperature separately from winding temperature; do not use a generic safety factor or Curie temperature as a working limit.
Next step

Convert the Preflight Into a Sample RFQ

Include the preflight values, joint map, envelope drawing, and duty-cycle assumptions. A practical early-program sequence is a catalog sample, evidence review, then custom interface decisions.

Inquiry Email

[email protected]

Subject: Humanoid robot actuator RFQ preflight and sample review

Include the preflight output, joint map, interface drawing, duty cycle, and target sample date.

Instant Chat

WhatsApp Engineering Support

Best for quick model-fit questions before a full RFQ email.