Choose product family, torque or force window, interfaces, and document request scope.
Solutions
Humanoid Actuator Solutions
Select humanoid robot application scenarios to review recommended actuator architectures, model-selection risks, and sample support direction.
Each solution page is written for buyer-side decisions: what to validate first, where actuator risk usually appears, and what data should be included in the initial RFQ to avoid quote loops.
Sourcing stages
Validate the application before sample release
Use product families for the baseline shortlist, keep this section focused on application risk, then move to OEM once sample controls are ready.
Map joint loads, sample gates, application risks, and candidate actuator evidence.
Current sectionSend validation context
Align sample quantity, NDA boundary, revision control, pilot supply, and repeat-order handoff.
Engineering Asset Status
Reference visuals, controlled records on request
Current site images are reference selection visuals for catalog navigation. They should not be treated as final factory photos, CAD drawings, test records, or lot-specific inspection documents. For shortlisted models, request the controlled packet tied to model code, drawing revision, test condition, and sample lot.
Public now
Reference visuals, product-family routes, RFQ class matrices, and validation checklists for early selection.
Request before PO
Controlled datasheet, drawing or CAD path, torque-speed or thermal record, wiring notes, and sample or OQC evidence.
Not claimed publicly
Verified factory-floor photos, teardown images, and lot-specific test reports are not presented as public evidence until real project assets exist.
Application Selection Workflow
- Map your robot joint, load case, and motion profile.
- Define performance acceptance criteria with measurable limits.
- Match actuator architecture to control stack, thermal envelope, mechanical packaging, and sample availability.
- Freeze prototype validation gates before PO release.
Application-to-Catalog Bridge
Use this bridge when the project brief starts from a robot joint or validation problem. It maps the application context to the first actuator architecture, product family, and sample gate that should be checked before RFQ pricing.
Hands, wrists, neck, and light ankle axes
Finger, wrist pitch/yaw, neck, light ankle, compact lab axes
- Torque / Force
- <50 Nm output class
- First Architecture
- Compact QDD, compact harmonic, or controller-matched module
- Catalog Path
- RFQ Priority
- Envelope, mass budget, low-speed smoothness, encoder resolution, and cable exit
- Sample Gate
- Backdrivability and current-limit behavior before interface customization
Shoulder, elbow, waist, and cable-through upper body
Shoulder, elbow, waist, torso, hollow-shaft wrist routing
- Torque / Force
- <50 to 150 Nm output class
- First Architecture
- Integrated rotary module or hollow-shaft joint actuator
- Catalog Path
- RFQ Priority
- Backlash, bore size, flange, cable bundle, protocol, and brake requirement
- Sample Gate
- Cable-through routing and repeated-position accuracy under load
Knee, ankle, hip, and bipedal load-bearing joints
Knee, ankle pitch/roll, hip pitch/roll/yaw, heavy leg test rigs
- Torque / Force
- 50-150 Nm and >150 Nm output classes
- First Architecture
- High-torque integrated rotary module, reducer module, or frameless motor stack
- Catalog Path
- RFQ Priority
- Continuous torque, overload duration, thermal path, brake behavior, impact load, and output bearing support
- Sample Gate
- Thermal rise and shock-load validation before pilot batch planning
Backdrivable force-control and QDD experiments
Force-control ankle, wrist, compliant shoulder, interaction and fall-response tests
- Torque / Force
- <50 to 150 Nm output class
- First Architecture
- QDD actuator, frameless outrunner, or low-ratio reducer stack
- Catalog Path
- RFQ Priority
- Reflected inertia, torque feedback, current bandwidth, protocol latency, and safety limits
- Sample Gate
- Force-control stability and low-speed torque ripple checks
Finger, linkage, and compact linear axes
Finger, thumb, compact end-effector linkage, roller-screw test fixture
- Torque / Force
- 40 N to 5 kN force / stroke-dependent
- First Architecture
- Micro linear actuator or compact roller-screw actuator
- Catalog Path
- RFQ Priority
- Stroke, force at speed, side load, backlash, noise, and holding behavior
- Sample Gate
- Mechanism fit and end-stop behavior before multi-axis kit ordering
Axial-flux and SMC motor-core R&D
Hip-light, knee R&D, compact high-torque demonstrator, 3D magnetic core trials
- Torque / Force
- Project-specific torque-density target
- First Architecture
- Axial-flux prototype path, SMC stator segment, or 3D magnetic core
- Catalog Path
- RFQ Priority
- OD, axial length, SMC grade, loss model, cooling path, tooling DFM, and validation method
- Sample Gate
- Material and concept validation before tooling commitment
| Application | Torque / Force | First Architecture | Catalog Path | RFQ Priority | Sample Gate | RFQ Route |
|---|---|---|---|---|---|---|
| Hands, wrists, neck, and light ankle axes Finger, wrist pitch/yaw, neck, light ankle, compact lab axes | <50 Nm output class | Compact QDD, compact harmonic, or controller-matched module | Envelope, mass budget, low-speed smoothness, encoder resolution, and cable exit | Backdrivability and current-limit behavior before interface customization | Start RFQ | |
| Shoulder, elbow, waist, and cable-through upper body Shoulder, elbow, waist, torso, hollow-shaft wrist routing | <50 to 150 Nm output class | Integrated rotary module or hollow-shaft joint actuator | Backlash, bore size, flange, cable bundle, protocol, and brake requirement | Cable-through routing and repeated-position accuracy under load | Start RFQ | |
| Knee, ankle, hip, and bipedal load-bearing joints Knee, ankle pitch/roll, hip pitch/roll/yaw, heavy leg test rigs | 50-150 Nm and >150 Nm output classes | High-torque integrated rotary module, reducer module, or frameless motor stack | Continuous torque, overload duration, thermal path, brake behavior, impact load, and output bearing support | Thermal rise and shock-load validation before pilot batch planning | Start RFQ | |
| Backdrivable force-control and QDD experiments Force-control ankle, wrist, compliant shoulder, interaction and fall-response tests | <50 to 150 Nm output class | QDD actuator, frameless outrunner, or low-ratio reducer stack | Reflected inertia, torque feedback, current bandwidth, protocol latency, and safety limits | Force-control stability and low-speed torque ripple checks | Start RFQ | |
| Finger, linkage, and compact linear axes Finger, thumb, compact end-effector linkage, roller-screw test fixture | 40 N to 5 kN force / stroke-dependent | Micro linear actuator or compact roller-screw actuator | Stroke, force at speed, side load, backlash, noise, and holding behavior | Mechanism fit and end-stop behavior before multi-axis kit ordering | Start RFQ | |
| Axial-flux and SMC motor-core R&D Hip-light, knee R&D, compact high-torque demonstrator, 3D magnetic core trials | Project-specific torque-density target | Axial-flux prototype path, SMC stator segment, or 3D magnetic core | OD, axial length, SMC grade, loss model, cooling path, tooling DFM, and validation method | Material and concept validation before tooling commitment | Start RFQ |
Application Validation Evidence Path
Use this path before releasing sample purchase orders. It separates application validation from generic catalog browsing so buyer teams know which documents, records, and interface inputs should be requested at each stage.
01 Application baseline
- Buyer Question
- Is the motion, load, envelope, and control case clear enough to shortlist an actuator architecture?
- Supplier Output
- Candidate architecture direction and provisional RFQ class shortlist.
- Documents to Request
- Model summary, envelope assumptions, torque-speed or force-stroke range, and accessory boundary.
- Decision Signal
- The buyer can narrow the discussion to one or two practical model families instead of a broad catalog scan.
02 Sample readiness
- Buyer Question
- Can the selected sample be powered, mounted, measured, and protected on the buyer bench?
- Supplier Output
- Sample packet with wiring, controller, encoder, brake, harness, and acceptance notes.
- Documents to Request
- Datasheet, pinout or wiring note, protocol note, accessory list, and initial inspection checklist.
- Decision Signal
- The sample order has enough context to avoid receiving an actuator that cannot be tested quickly.
03 Application validation
- Buyer Question
- Does the actuator survive the buyer-side duty case with acceptable heat, motion quality, and interface behavior?
- Supplier Output
- Validation evidence matched to the application risk, not a generic performance claim.
- Documents to Request
- Thermal note, load or backlash check, brake or holding note, control-loop assumption, and revision ID.
- Decision Signal
- The team can decide whether to continue, modify the interface, or switch architecture before pilot planning.
04 Pilot control
- Buyer Question
- Will the accepted sample configuration stay traceable when moving to multi-axis or pilot quantities?
- Supplier Output
- Revision-controlled drawing boundary, inspection record type, and pilot-order acceptance checklist.
- Documents to Request
- Revision baseline, outgoing inspection format, packaging/accessory list, and controlled CAD path if needed.
- Decision Signal
- The buyer knows which configuration was validated and which changes require requalification.
| Stage | Buyer Question | Supplier Output | Documents to Request | Decision Signal |
|---|---|---|---|---|
| 01 Application baseline | Is the motion, load, envelope, and control case clear enough to shortlist an actuator architecture? | Candidate architecture direction and provisional RFQ class shortlist. | Model summary, envelope assumptions, torque-speed or force-stroke range, and accessory boundary. | The buyer can narrow the discussion to one or two practical model families instead of a broad catalog scan. |
| 02 Sample readiness | Can the selected sample be powered, mounted, measured, and protected on the buyer bench? | Sample packet with wiring, controller, encoder, brake, harness, and acceptance notes. | Datasheet, pinout or wiring note, protocol note, accessory list, and initial inspection checklist. | The sample order has enough context to avoid receiving an actuator that cannot be tested quickly. |
| 03 Application validation | Does the actuator survive the buyer-side duty case with acceptable heat, motion quality, and interface behavior? | Validation evidence matched to the application risk, not a generic performance claim. | Thermal note, load or backlash check, brake or holding note, control-loop assumption, and revision ID. | The team can decide whether to continue, modify the interface, or switch architecture before pilot planning. |
| 04 Pilot control | Will the accepted sample configuration stay traceable when moving to multi-axis or pilot quantities? | Revision-controlled drawing boundary, inspection record type, and pilot-order acceptance checklist. | Revision baseline, outgoing inspection format, packaging/accessory list, and controlled CAD path if needed. | The buyer knows which configuration was validated and which changes require requalification. |

Humanoid Prototype Actuator Sourcing
A sourcing path for humanoid robot teams that need several actuator sizes quickly for prototype trials, bench testing, and first walking or manipulation experiments.
For early-stage teams that are still comparing models and need practical sourcing support instead of a single custom actuator quote.
- Joint-map based actuator shortlist for the whole robot
- Fast sample sourcing before full custom engineering
- Tradeoff notes for torque density, cost, availability, and integration risk
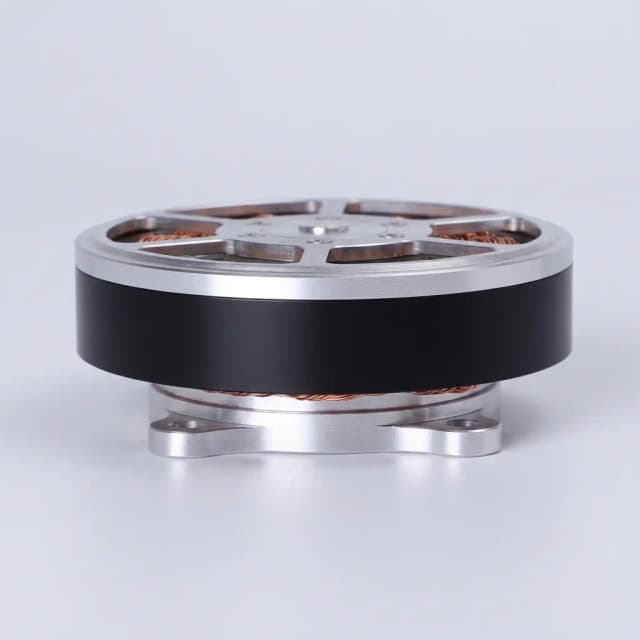
Bipedal Leg Joint Actuators
Actuator sourcing guidance for humanoid hips, knees, ankles, and balance joints where overload, stiffness, thermal behavior, and fast replacement matter.
For teams building lower-body prototypes that need actuator samples capable of repeated gait testing.
- Hip, knee, and ankle actuator shortlist support
- Overload, impact, brake, and thermal criteria for walking tests
- Replacement and spare-sample planning for aggressive prototype cycles
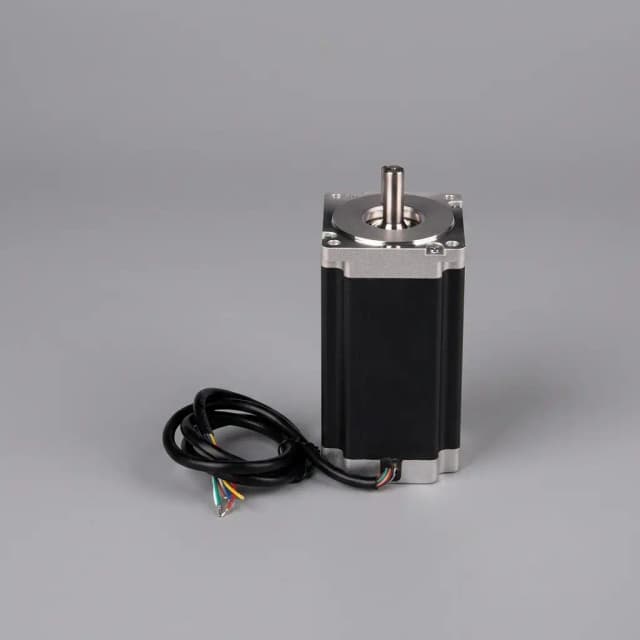
Humanoid Arm and Hand Actuators
Compact actuator selection for humanoid arms, wrists, neck modules, and end-effector support where low mass and smooth control are critical.
For teams optimizing upper-body weight, smooth motion, and quick sample access.
- Upper-limb actuator sizing by payload, reach, and mass budget
- Compact module comparison for shoulders, elbows, wrists, and neck axes
- Small actuator and controller kit support for manipulation prototypes

Force-Control Actuator Selection
Selection support for humanoid actuators where torque sensing, compliance, backdrivability, low ratio design, and controller bandwidth drive the buying decision.
For robotics engineers who care more about controllable interaction than simply buying the highest-ratio gearbox.
- QDD and low-ratio actuator comparison for compliant robotics
- Encoder, current control, and driver bandwidth review
- Risk notes for teams moving from simulation to physical force control

Robotics Lab Sample Kits
Sample-kit sourcing for labs and startups that need actuator modules, controllers, encoders, reducers, brakes, and harnesses for quick bench validation.
For buyers who need two to twenty actuator samples with enough accessories to run meaningful tests quickly.
- Matched actuator and controller sample kits for faster bench bring-up
- Small-quantity support before annual volume and custom tooling are known
- Documentation-oriented RFQ flow for overseas robotics teams
Solution Comparison Snapshot
Humanoid Prototype Actuator Sourcing
- Primary Buyer Focus
- For early-stage teams that are still comparing models and need practical sourcing support instead of a single custom actuator quote.
- Key Metric
- Selection breadth: Multiple actuator families per joint group
- Why It Matters
- Prototype teams need options because the final robot architecture often changes after the first tests.
Bipedal Leg Joint Actuators
- Primary Buyer Focus
- For teams building lower-body prototypes that need actuator samples capable of repeated gait testing.
- Key Metric
- Overload handling: Defined by peak duration and thermal path
- Why It Matters
- Leg joints see aggressive test loads and need practical overload margins.
Humanoid Arm and Hand Actuators
- Primary Buyer Focus
- For teams optimizing upper-body weight, smooth motion, and quick sample access.
- Key Metric
- Mass budget: Joint and payload dependent
- Why It Matters
- Each upper-body actuator affects downstream torque and payload calculations.
Force-Control Actuator Selection
- Primary Buyer Focus
- For robotics engineers who care more about controllable interaction than simply buying the highest-ratio gearbox.
- Key Metric
- Control bandwidth: System dependent
- Why It Matters
- Force-control quality depends on the actuator, driver, encoder, and robot controller together.
Robotics Lab Sample Kits
- Primary Buyer Focus
- For buyers who need two to twenty actuator samples with enough accessories to run meaningful tests quickly.
- Key Metric
- Kit completeness: Actuator plus matched accessories
- Why It Matters
- Prototype teams lose time when they receive a motor but still need to source a compatible driver or encoder interface.
| Solution | Primary Buyer Focus | Key Metric | Why It Matters |
|---|---|---|---|
| Humanoid Prototype Actuator Sourcing | For early-stage teams that are still comparing models and need practical sourcing support instead of a single custom actuator quote. | Selection breadth: Multiple actuator families per joint group | Prototype teams need options because the final robot architecture often changes after the first tests. |
| Bipedal Leg Joint Actuators | For teams building lower-body prototypes that need actuator samples capable of repeated gait testing. | Overload handling: Defined by peak duration and thermal path | Leg joints see aggressive test loads and need practical overload margins. |
| Humanoid Arm and Hand Actuators | For teams optimizing upper-body weight, smooth motion, and quick sample access. | Mass budget: Joint and payload dependent | Each upper-body actuator affects downstream torque and payload calculations. |
| Force-Control Actuator Selection | For robotics engineers who care more about controllable interaction than simply buying the highest-ratio gearbox. | Control bandwidth: System dependent | Force-control quality depends on the actuator, driver, encoder, and robot controller together. |
| Robotics Lab Sample Kits | For buyers who need two to twenty actuator samples with enough accessories to run meaningful tests quickly. | Kit completeness: Actuator plus matched accessories | Prototype teams lose time when they receive a motor but still need to source a compatible driver or encoder interface. |
Inquiry Email
Subject: Solution Inquiry - Humanoid Prototype Actuator Sourcing
This inquiry started from an application page. Keep the request anchored to the robot scenario, validation risk, and candidate actuator path. Source context: Humanoid Prototype Actuator Sourcing.
Instant Chat
WhatsApp Engineering Support
Best for quick model-fit questions before a full RFQ email.